CORE PRODUCT FAMILY
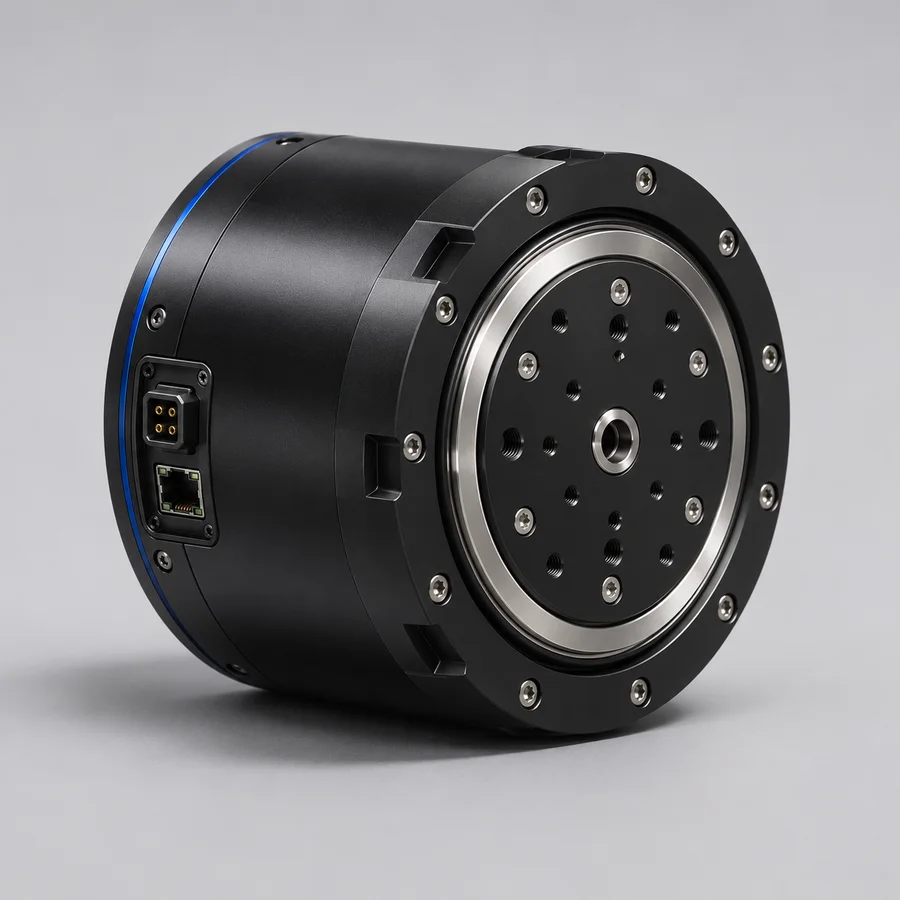
Integrated robotic joint
Complex motion. Simply integrated.
Motor, driver, encoder and planetary reducer in one integrated module for robotic motion.
Selection depends on operating conditions and configuration; refer to approved specifications.
01 / SPECIFICATIONS
Joint module specifications
Explore output characteristics, electrical configuration and control interfaces. Configuration and test conditions are subject to the agreed product documentation.
Electrical and motion parameters
| Parameter | Specification | Unit |
|---|---|---|
| Operating voltage | 12-60 | V |
| Rated voltage | 48 | V |
| Rated torque | 20 | N·m |
| Rated speed | 80 | RPM |
| Rated current | 7 | A(rms) |
| Peak torque (>3s) | 70 | N·m |
| Peak speed | 117 | RPM |
| Peak current | 25 | A(rms) |
| Torque constant | 2.93 | Nm/A |
| Back-EMF constant | To be confirmed | Vrms/Krpm |
| Speed constant | 87 | rpm/V |
| Motor constant | To be confirmed | Nm/√W |
| Electromechanical time constant | To be confirmed | ms |
| Electrical time constant | To be confirmed | ms |
| Pole pairs | 14 | — |
| Winding connection | Star connection | — |
| Phase resistance | 0.9 | Ω |
| Phase inductance | 0.41 | mH |
Transmission and mechanical parameters
| Parameter | Specification | Unit |
|---|---|---|
| Reduction ratio | 36 | — |
| Reducer backlash | 10 | Arcmin |
| Output bearing | Crossed roller bearing | — |
| Backdrive torque | 0.7 | N·m |
| Rotational inertia | To be confirmed | g.cm² |
| Mass | 530 | g |
| Axial load | 4.8 | kN |
| Radial load | 2.1 | kN |
Control and interfaces
| Parameter | Specification | Unit |
|---|---|---|
| Control bandwidth | 2000 | Hz |
| Communication | CAN | — |
| Encoder type | Dual-encoder configuration | — |
| Encoder resolution | 14 | bit |
| CAN connector | XT30(2+2)PB-M | — |
| USB connector | SH1.0-4P | — |
| Power connector | XT30(2+2)PB-M | — |
| Control modes | Servo mode Speed mode Torque mode Torque-position hybrid mode | — |
| Protection functions | Overvoltage protection Overcurrent protection Overtemperature protection | — |
Operating and protection parameters
| Parameter | Specification | Unit |
|---|---|---|
| Duty type | S2 | — |
| Ingress protection | IP40 | — |
| Cooling method | IC410 | — |
| Ambient operating temperature | -20°C~50°C | — |
| Insulation class | F | — |
| Dielectric strength | 500V1kHz1A1ms Confirm test conditions for the selected configuration. | — |
| Insulation resistance | 100MΩ 20°C | — |
| Temperature sensor model | NTC MF52B 103F3950 | — |
| Noise | 60dB/1.0m Confirm operating and measurement conditions during selection. | — |
Unspecified values will be confirmed during selection. Duty cycle, load, environment and installation conditions may affect performance and should be reviewed for the application.
02 / ARCHITECTURE
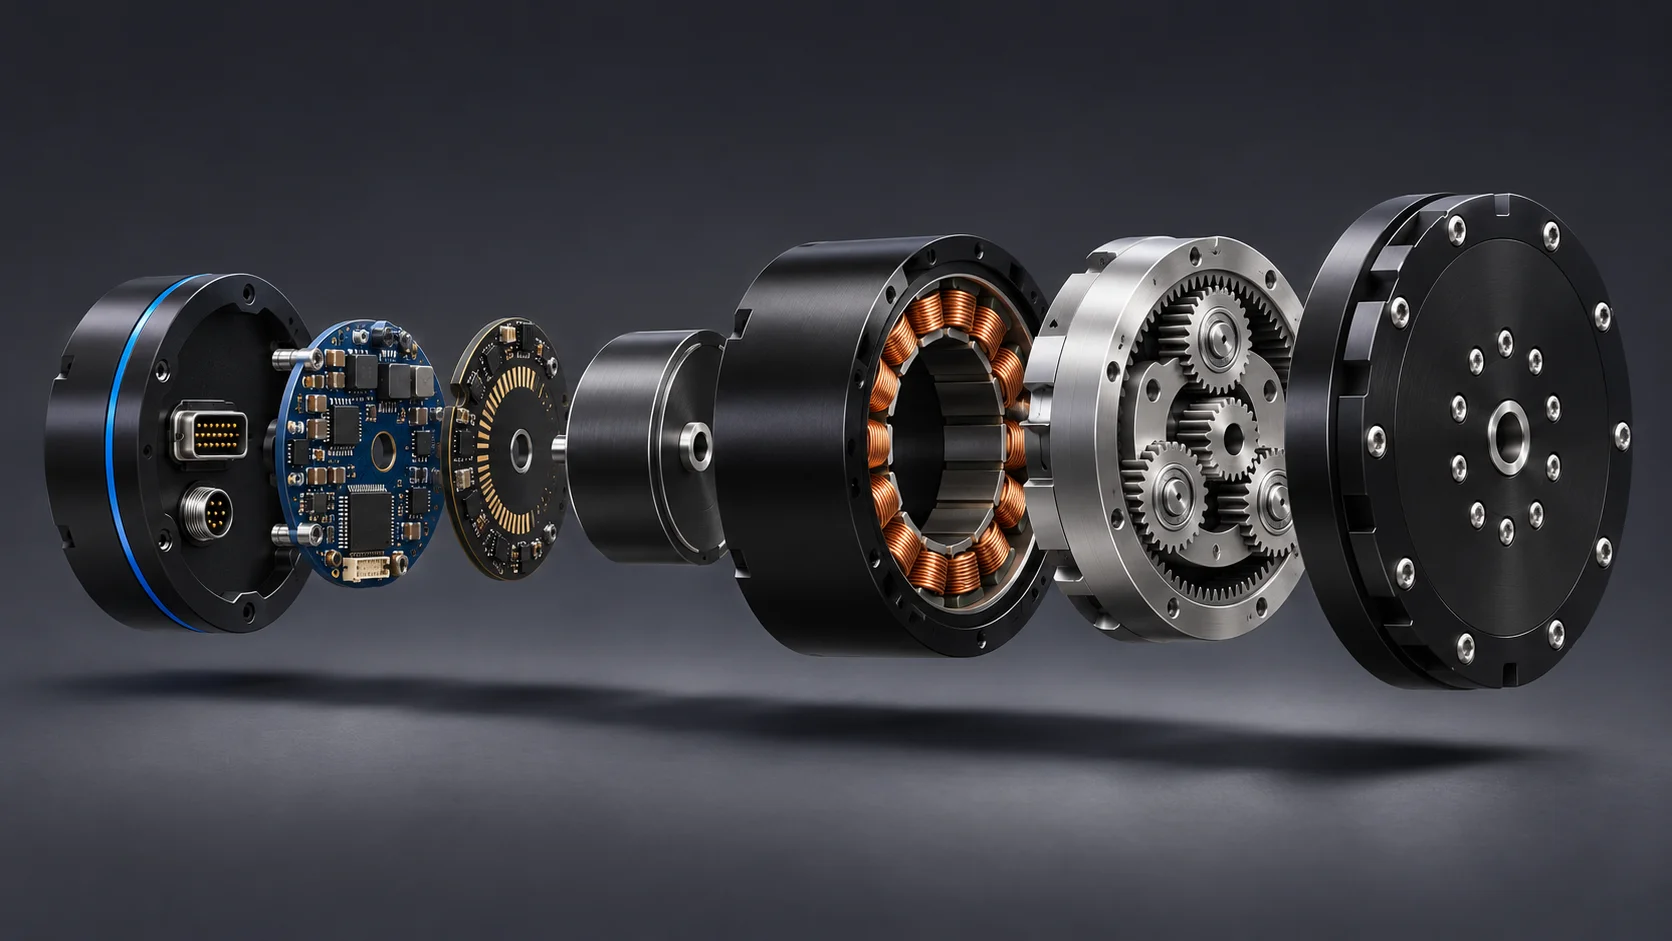
Understand the product from within.
Motor, driver, encoder and planetary reducer working together in one joint.
03 / TECHNICAL RESOURCES
Turn requirements into engineering detail.
04 / SELECTION FAQ
Before you select.
What information should I provide?+
Share the application, load or torque, speed, installation space, power supply, interface, quantity and schedule. Drawings can be shared through the confirmed contact channel.
How do I obtain drawings and technical documents?+
Contact JEOLINK to confirm the product and configuration. Use approved documentation for dimensions, construction and performance.
How are customization and delivery confirmed?+
Submit your requirements to review the technical scope, sample or production quantity, validation and schedule. This website does not constitute a quotation or delivery commitment.